Automatic calibration systems for strain-gauge-based force & torque sensors used in humanoid robots and robot dogs — 0.01% programmable resistor bridge simulators, 32-bit multi-channel DAQ for closed-loop readback, and CAN/ETH control gateways. One sensor calibrated in seconds instead of minutes. Also proven in bridge & tunnel vibration monitoring.
Quickly find the modules you need by product type
Purpose-built for robot & robot-dog sensor calibration and testing — also serving bridge & tunnel vibration monitoring
10 Channel | 32-bit | Closed-Loop Sensor Test
View Details →
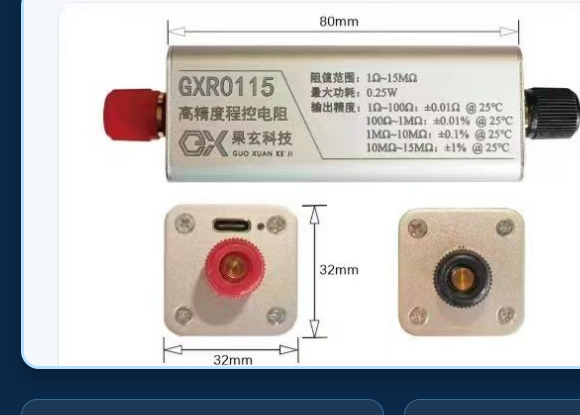
1Ω–15MΩ | 2 mΩ Step | 0.01% Accuracy
View Details →
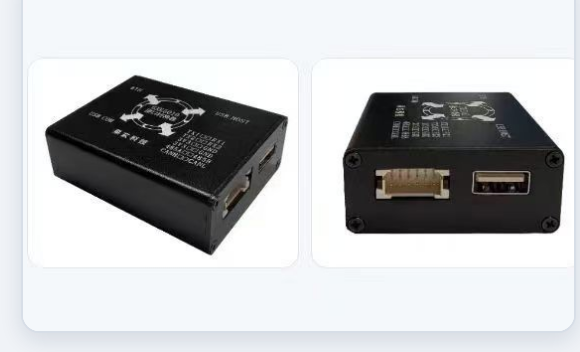
ETH | USB | CAN 1Mbps | RS485 — Robot Joint Bus Ready
View Details →
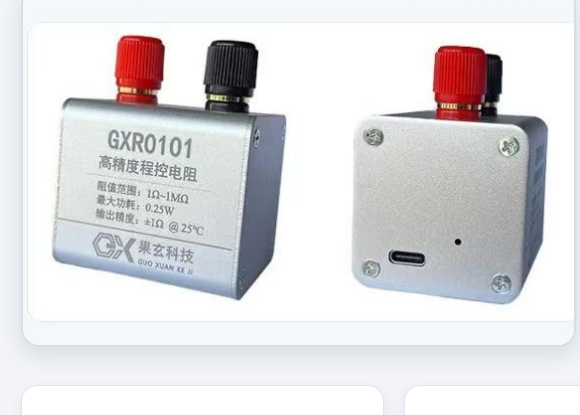
1Ω–1MΩ | ±1Ω | Force Sensor Calibration
View Details →
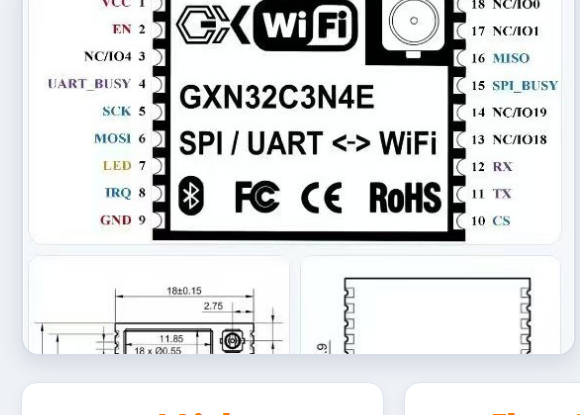
20 Mbps TCP | SPI/UART to WiFi | 4-Way TCP/UDP
View Details →From laboratory to industrial sites — covering diverse measurement & control needs
Automatic production-line calibration of strain-gauge-based 6-axis, joint torque and 1-axis force sensors: programmable resistors simulate Wheatstone bridge outputs while 32-bit DAQ reads back synchronously — one sensor calibrated in ~5 seconds at 0.01% accuracy, with full data traceability.
Multi-channel static/dynamic performance testing for joint modules and reducers — torque, temperature and vibration logging with CAN-bus digital output cross-check, ideal for endurance bench integration.
The same 32-bit DAQ and remote calibration hardware, field-proven in structural health monitoring (SHM): long-term vibration data acquisition for bridges and tunnels with remote sensor calibration.